Preparing for releasePartially verified
SteadyWin CAN motors
SteadyWin CAN motor control has been implemented and tested in development, opening another path alongside conventional step/direction drives.
View GDZ810 · GIM8108-6 details →HARDWARE
Available products, hardware in fabrication, and planned expansion live in one catalog. Purchase status and JetFlight validation are shown separately.
SteadyWin CAN motor control has been implemented and tested in development, opening another path alongside conventional step/direction drives.
View GDZ810 · GIM8108-6 details →A current plasma controller in the JetCad store. JetFlight use requires the matching adaptor, firmware, and a validated configuration.
View Gen5 details →The integrated ESP32-S3 N8R2 adaptor now being fabricated. It maps JetFlight motion and plasma I/O to a 3.3 V carrier interface.
View V2 · N8R2 details →The prototype combination used for JetFlight's first physical cuts. It establishes real motion and cutting evidence, but it is not a current retail configuration.
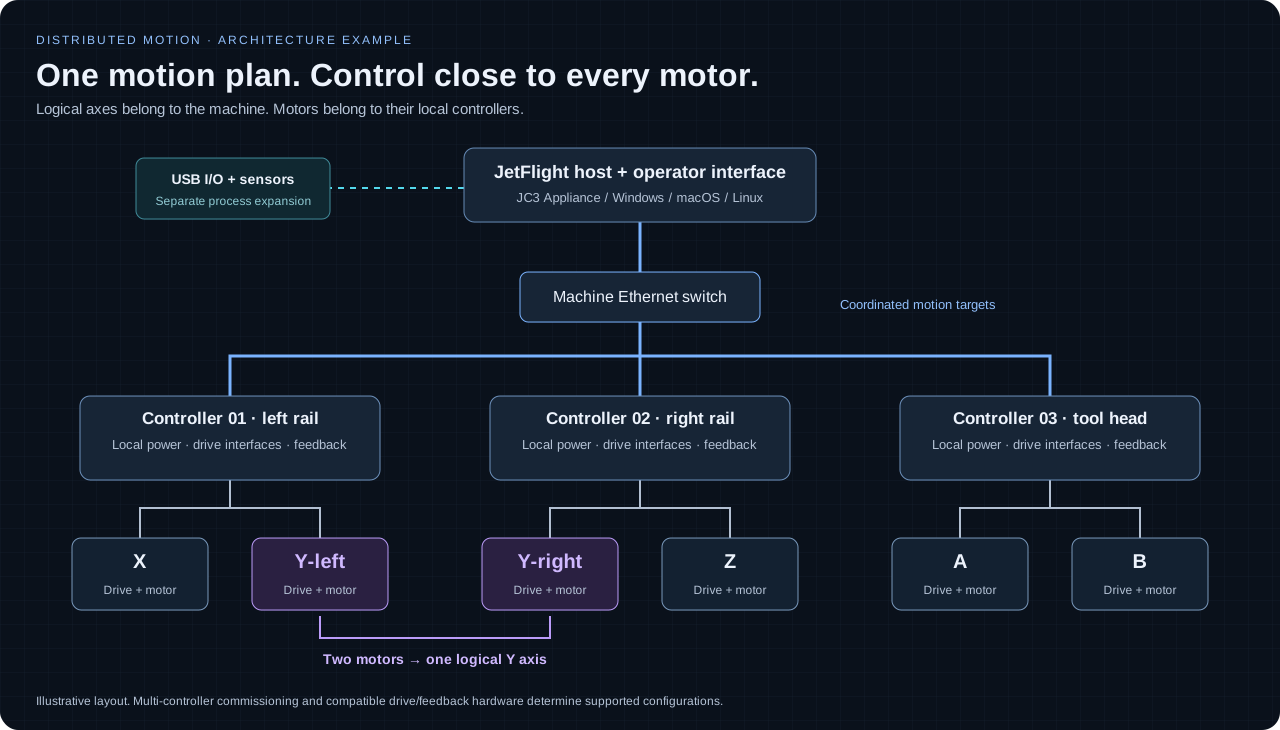
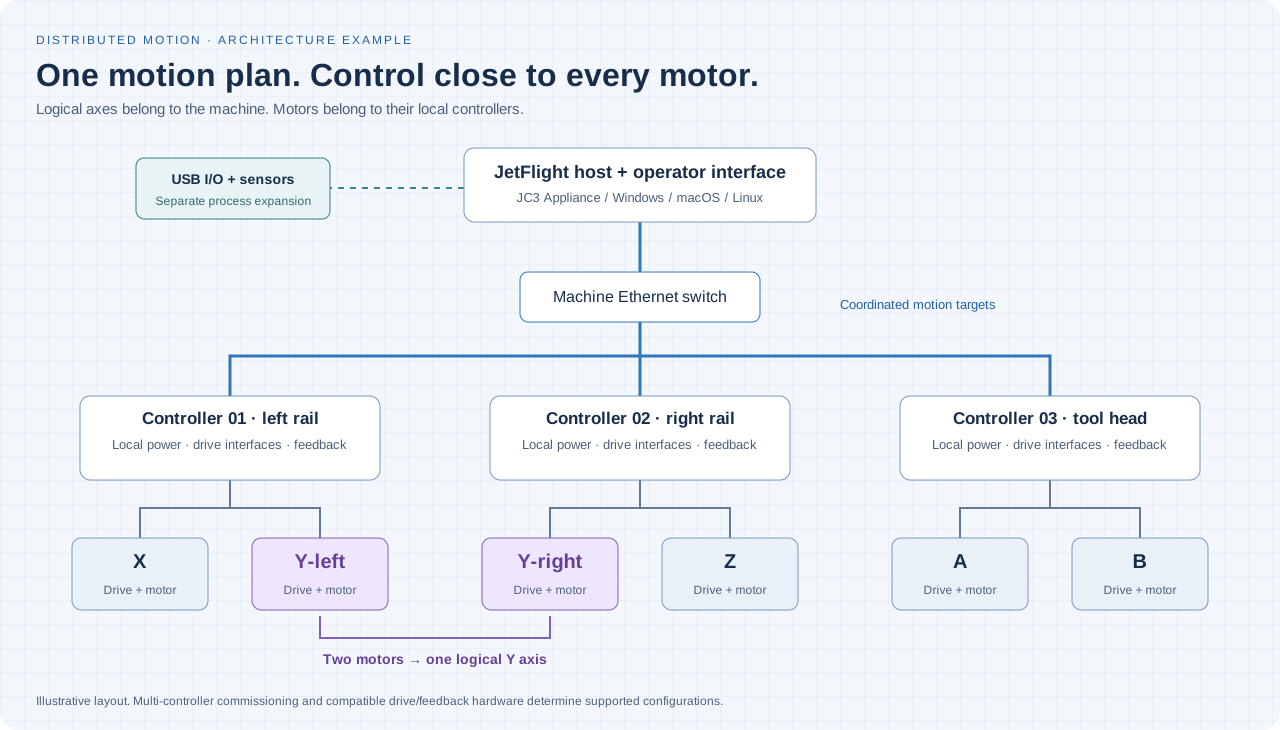
View Prototype details →A planned machine-side node for placing motion control near distant joints and reducing long signal runs.
View Planned details →Planned hardware for broader drive and feedback interfaces, including direct feedback where the board and firmware support it.
View Planned details →Planned Ethernet and USB expansion for adding machine I/O without exhausting one central breakout board.
View Planned details →A planned lower-cost entry point for simpler machines, using the same JetFlight software and documentation model.
View Planned details →